 Skip to content


- Home
- UAS WARFARE
- SAF-DRONE
Autonomy Testing, Development, Validation and Verification Environment.
Author Drone 'Intelligence' in the Application as a Hierarchical Task Network (HTN).
Test, Refine, Repeat in Simulation Environments.
Deploy Exact Code to the Real Drone/Swarm.
In Effect, an 'Operating System for Autonomy'.
YouTube
This content is blocked because YouTube cookies have not been accepted.
Capabilities:
- Autonomy Testing, Development, Validation and Verification Environment
- Author Drone ‘Intelligence’ in the Application as a Hierarchical Task Network (HTN)
- Test, Refine, Repeat in Simulation Environments
- Deploy Exact Code to the Real Drone/Swarm
- In effect, an ‘Operating System for Autonomy’.
Accelerating the Development & Deployment of Autonomous UAS Capabilties
SAF-DRONE™ is a modular autonomy engineering framework that enables the rapid development, integration, testing and deployment of autonomous and semi-autonomous drone capabilities.
Combining intuitive behaviour design with high-fidelity simulation and systematic verification and validation, SAF-DRONE™ allows developers to build, test and refine autonomous behaviours in a repeatable virtual environment before deploying them onto real platforms.
Key Capabilities
Accelerating Autonomy Development
SAF-DRONE™ complements drone hardware by providing the software architecture, integration framework and development environment that enables customers to assemble and evolve autonomous behaviours more quickly.
DEVELOP. TEST. ASSURE. DEPLOY.
Combining intuitive behaviour design with high-fidelity simulation and systematic verification and validation, SAF-DRONE™ allows developers to build, test and refine autonomous behaviours in a repeatable virtual environment before deploying them onto real platforms.
Key Capabilities
- Intuitive Behaviour Design: Create complex autonomous behaviours using Hierarchical Task Networks (HTNs), combining reusable behaviours into sophisticated mission capabilities.
- Rapid Simulation & Testing: Test, refine and optimise autonomous behaviours through repeatable simulation, including complex scenarios and edge cases.
- Verification & Validation: Systematically evaluate behaviour performance, safety and reliability, generating evidence to support autonomy assurance.
- Simulation-to-Real Deployment: Execute the same autonomy code in simulation and on real platforms, reducing integration risk and accelerating development.
- Modular, Open Architecture: Integrate different airframes, sensors, avionics and autonomy components through a flexible, hardware-agnostic framework.
Accelerating Autonomy Development
SAF-DRONE™ complements drone hardware by providing the software architecture, integration framework and development environment that enables customers to assemble and evolve autonomous behaviours more quickly.
DEVELOP. TEST. ASSURE. DEPLOY.
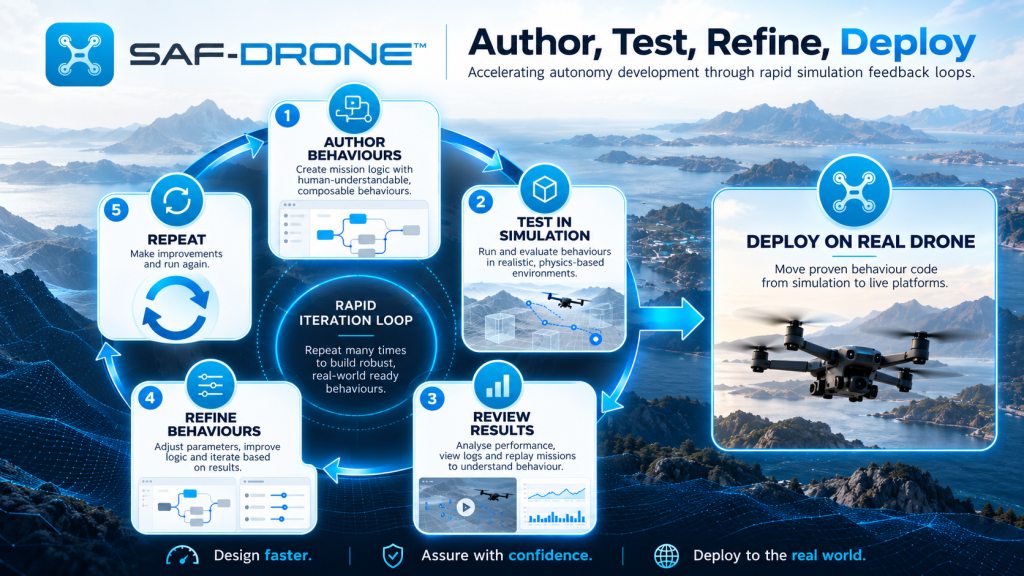
SAF-DRONE™ Development Cycle
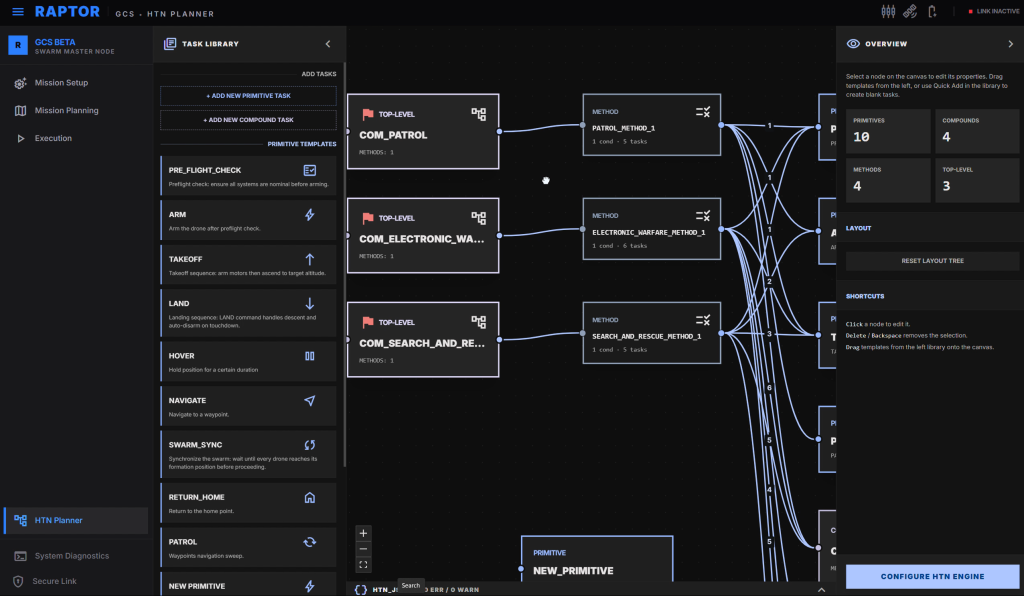
Author Autonomous Behaviours, Composed from your Library of Lower Level Behaviours
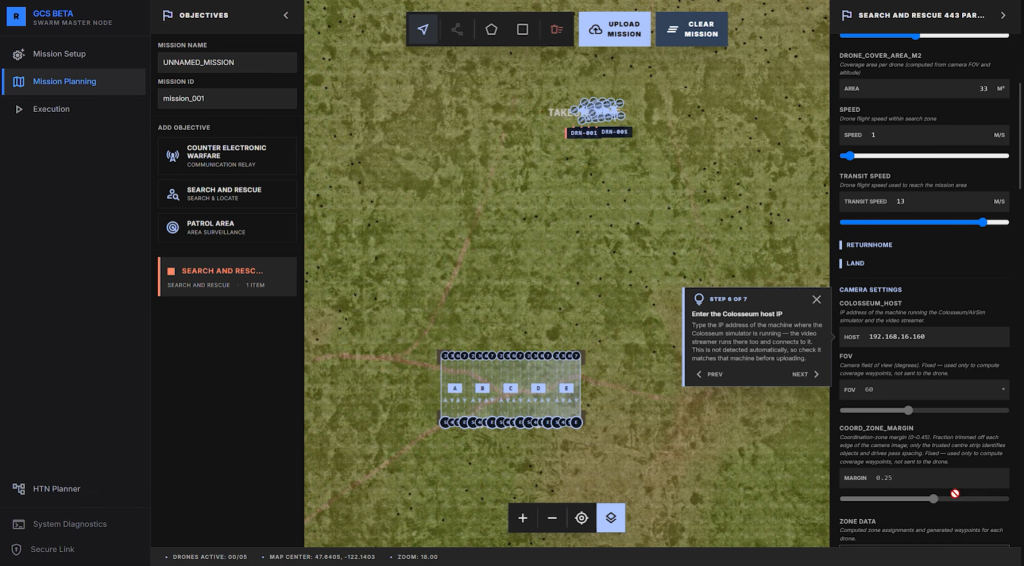
Assign Drone Swarm Objectives
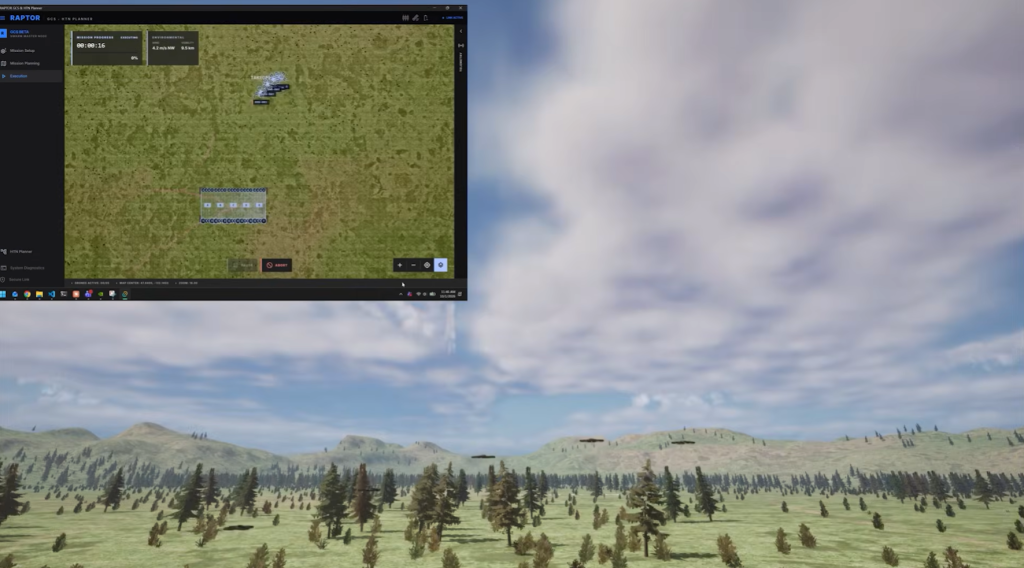
Execute Mission in Simulation
Enquiries?
For further information, or to book a demo, please do not hesitate to contact us!
Related SimCentric Products
SAF-TAC
SAF-TAC™ - Virtual Training Solution, Based On Unreal Engine
SAF-SOLO
SAF-SOLO™ - Scalable Individual Training Using Stand-Alone VR Headsets
SAF-TAC C-UAS
SAF-TAC™ C-UAS – Complete Counter UAS Training system
